Planet Routes
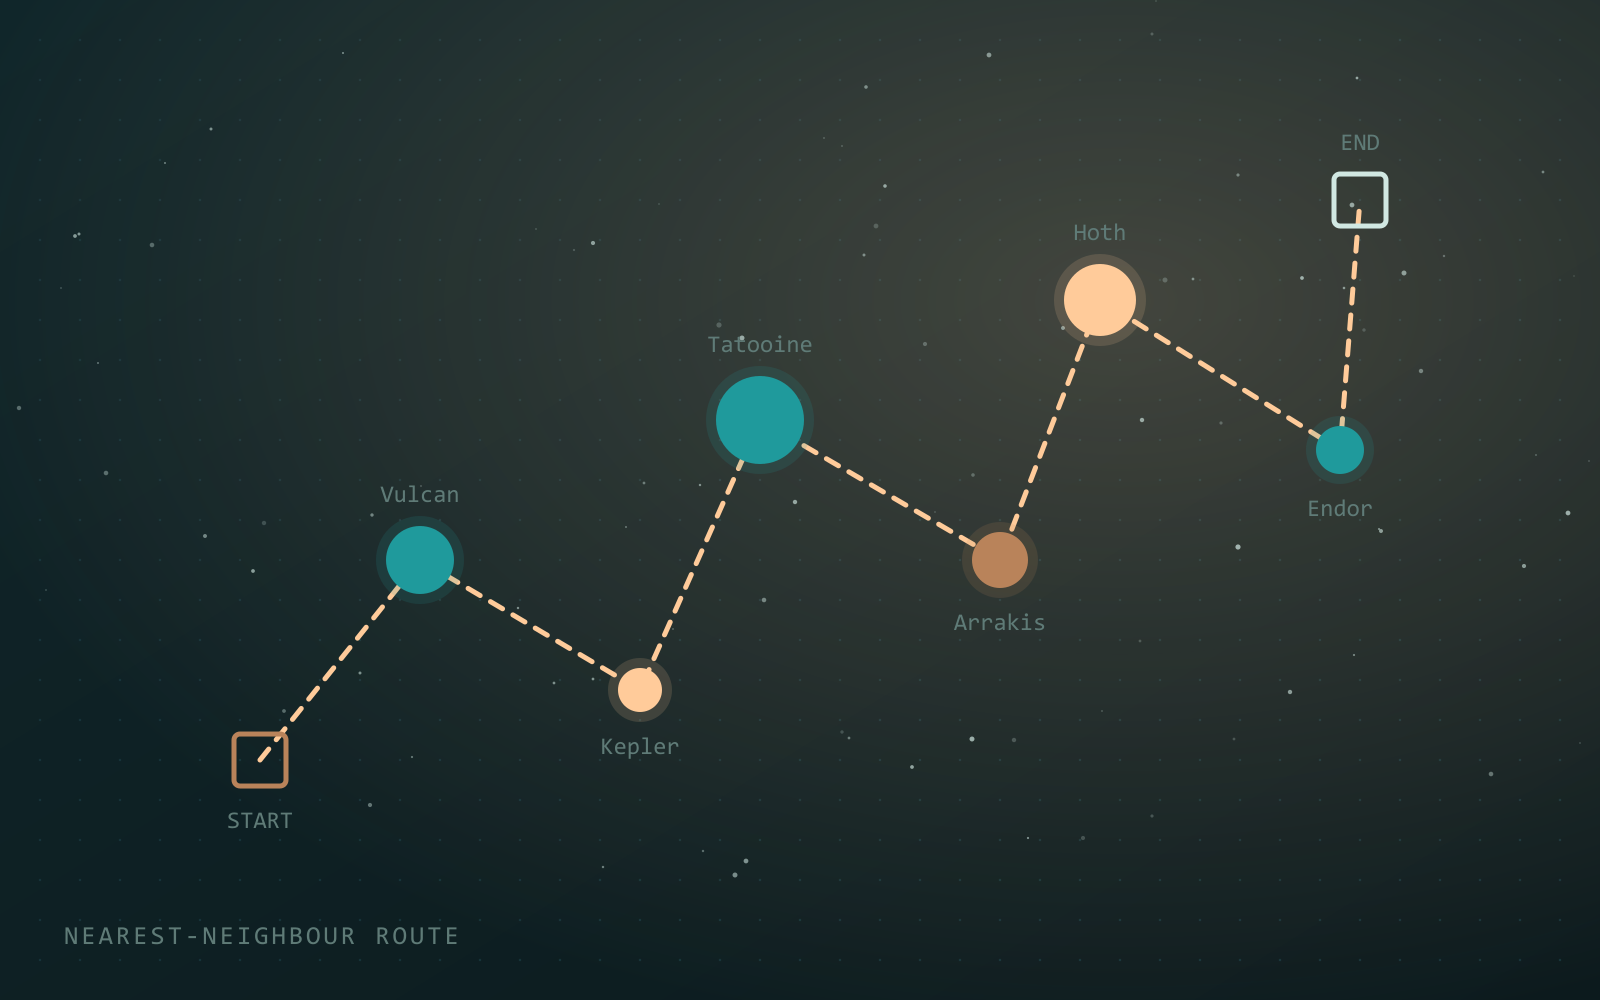
Reads a mission grid, planet locations and planet names from file, draws the map, then plans a route from start to finish by always travelling to the closest planet not yet visited.
- Stack
- C++AlgorithmsFile I/O
- Highlights
- Nearest-neighbour routing by Euclidean distance
- Grid rendering of the mission map
- Structs for planets and missions, parsed from input files
The problem
Visit every planet on the map, starting and ending at fixed points, with a route that is short without being exhaustively optimal.
Approach
Parse, then plan. Mission bounds, planet coordinates and planet names come
from separate input files and are loaded into Planet and Mission structs.
Out-of-bounds planets are filtered before planning starts.
Nearest neighbour. From the current position, the planner picks the closest unvisited planet by Euclidean distance, moves there, marks it visited, and repeats. It's a greedy heuristic rather than an optimal tour, but it's fast and good enough in practice.
Readable output. The program prints the map as a character grid, then the journey step by step, from "Start at" to "End at".